
楊其龍
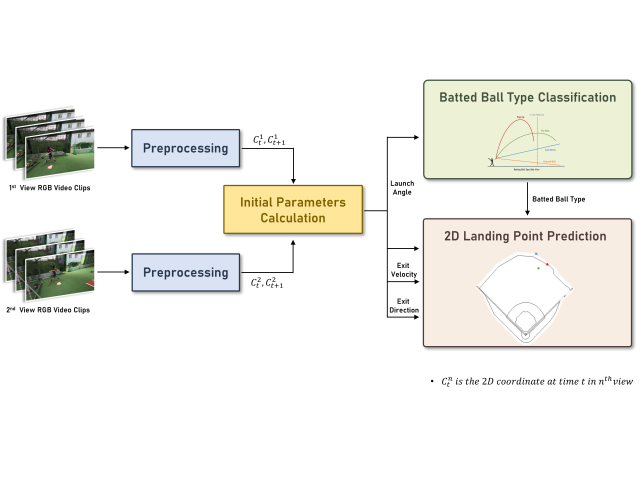
Baseball is often limited by weather conditions and a shortage of available fields, and leads to a supply-demand imbalance. As a result, many college teams and amateur baseball clubs are frequently forced to conduct batting practice in indoor. However, the confined indoor space prevents the ball from completing its full trajectory after being hit, and makes it difficult to determine its final landing point. While there are various batted ball tracking devices on the market that can be used indoors, these systems are often expensive and not portable enough for training at different locations. To provide an effective and cost-efficient solution for obtaining batting- related data, this paper proposes a prediction model that reconstructs the baseball’ s flight path and landing point using only two cameras. This paper proposes a high-accuracy baseball trajectory reconstruction and landing point prediction model using only two cameras. The proposed method is divided into two main components: Initial Parameters Calculation and Landing Point Prediction. In the initial parameter calculation phase, we incorporate a Region of Interest (ROI) constraint to enhance the 2D detection accuracy of the baseball. For landing point prediction, a Multilayer Perceptron (MLP) serves as the backbone prediction model, this design ensures both real-time computational efficiency and the ability of the neural network to independently learn and represent the complex physical parameters involved in the baseball’s flight trajectory. Additionally, a Batted Ball Type Classifier is introduced before landing point prediction to achieve accurate predictions across different dataset sizes and training conditions. With the constraint of using only two GoPro cameras, the proposed method effectively balances computational efficiency while ensuring high accuracy in both baseball detection and landing point prediction.
 MIS Lab